tbottest.tc - Testcases
tbot-test come bundled with a bunch of testcases. Here is an overview:
Common Testcases
- tbottest.tc.common.escape_ansi(line: str) str[source]
helper for escaping ansi codes
- Parameters:
line – string which should be escaped
- Returns:
ansi escaped string
- tbottest.tc.common.search_string_in_multiline(search, lines) bool[source]
search string search in multiline lines
- Parameters:
search – string to search
lines – multiline string, in which we search the string
- Returns:
True if found else False
- tbottest.tc.common.search_multistring_in_multiline(searches, lines) bool[source]
search mutliple strings in mutli liner
- Parameters:
search – array of strings to search in lines
lines – multiline string, in which we search the string
- Returns:
True if all strings are found else False
- exception tbottest.tc.common.ExecDeathStringError(match: bytes, args: Tuple[Any, ...])[source]
Bases:
ExceptionRaised by exec_check()/exec0_check() when one of the given death_strings appears in a command’s output before the command finished on its own.
- tbottest.tc.common.exec_check(mach: Any, *args: Any, death_strings: List[Any]) Tuple[int, str][source]
Like
mach.exec(*args), but aborts immediately by raising ExecDeathStringError as soon as any string in death_strings appears in the command’s output, instead of waiting for the command to finish on its own.Works for any machine exposing
.chand.exec(), e.g. Linux shells (linux.LinuxShell) and U-Boot shells (board.UBootShell).- Parameters:
mach – machine to run the command on
death_strings – list of strings/patterns which, if found in the command’s output, abort the command immediately
- tbottest.tc.common.exec0_check(mach: Any, *args: Any, death_strings: List[Any]) str[source]
Like
mach.exec0(*args), but aborts immediately by raising ExecDeathStringError as soon as any string in death_strings appears in the command’s output, instead of waiting for the command to finish on its own.Works for any machine exposing
.chand.exec0(), e.g. Linux shells (linux.LinuxShell) and U-Boot shells (board.UBootShell).- Parameters:
mach – machine to run the command on
death_strings – list of strings/patterns which, if found in the command’s output, abort the command immediately
- tbottest.tc.common.lx_cmd_exists(lnx: LinuxShell, cmd) bool[source]
check if command on linux machine exists
- Parameters:
lnx – Linux machine we run on
cmd – command name
- tbottest.tc.common.lx_devmem2_get(lnx: LinuxShell, addr: str, typ: str) str[source]
use devmem2 to read value from addr, or devmem (busybox) if the machine has no devmem2
- Parameters:
lnx – Linux machine we run on
addr – address we act on
type –
devmem2 typeaccess operation type : [b]yte, [h]alfword, [w]ord, [l]ongdevmem knows b, h and w only (width 8, 16, 32)
- Returns:
value
- tbottest.tc.common.lnx_check_revfile(lnx: LinuxShell, revfile, difffile=None, timeout=None) bool[source]
compare the register values defined in revfile with the values read on Linux machine with devmem2
If difffile != None write differences found into this file.
see also:
tbottest.tc.generic_board.generic_lnx_check_dump_files()- Parameters:
lnx – Linux machine we run on
revfile – reference file we use
diffile – if not None, file in which testcase writes differences found
timeout – timeout between devmem2 calls
- tbottest.tc.common.lnx_command_check_dump_file(lnx: LinuxShell, revfile, log) int[source]
opens dump file from a command and compares the output with the current run of the command.
print the differences
- Parameters:
lnx – Linux machine we run on
revfile – revfile with reference content
log – collected log (return from lnx.exec0())
- tbottest.tc.common.lnx_command_create_dump_file(lnx: LinuxShell, revfile, log) bool[source]
create a file revfile which contains the output of a command.
see also:
tbottest.tc.common.lnx_create_command_check_dump_file()- Parameters:
lnx – Linux machine we run on
revfile – created revfile
log – collcected log (return from lnx.exec0()
- tbottest.tc.common.lnx_create_revfile(lnx: LinuxShell, revfile, startaddr, endaddr, mask='0xffffffff', readtype='w') bool[source]
create a reference file revfile with values read on Linux machine with devmem2 from startaddr to endaddress, and readtype “w”
see also:
tbottest.tc.generic_board.generic_lnx_create_dump_files()- Parameters:
lnx – Linux machine we run on
revfile – created revfile
startaddr – address from which the testcase starts dumping
endaddr – address on which the testcase stops dumping
mask – written mask into revfile
readtype – used tpye for devmem2 call, default “w”
- tbottest.tc.common.generic_machine_dump(typ, machine, startaddr, endaddr, inc, gaps, filename) None[source]
generate a generic register dump from a linux or U-Boot machine. starting from startaddr until endaddr. Increment in each step the current address with the value in inc.
machine contains a linux or U-Boot machine, simply the machine from which you want to create the registerdump.
On Linux machine the value is read with devmem2 tool, in U-Boot with the md command.
The testcase writes the address and the value into the file with filename filename.
It is possible to define gaps (to prevent accessing registers which create a core dump, or simply to not dump registers you are not interested in!
With this approach you can dump register in linux and U-Boot and simply compare the 2 resulting txt files. Or with testcase generic_machine_dump_write write for example a register dump, created on a linux machine to an U-Boot machine.
example:
lcdif2_gaps = [
    {"iaddr":"0x32e9002c", "naddr":"0x32e90030"},
    {"iaddr":"0x32e90038", "naddr":"0x32e90200"},
    {"iaddr":"0x32e90204", "naddr":"0x32e90208"},
    {"iaddr":"0x32e90218", "naddr":"0x32e9021c"},
]
So if new address is equal to “iaddr”, it gets replaced with the value in naddr.
- Parameters:
type – values “linux” or “u-boot”, we should detect this from machine parameter
machine – machine we run on
startaddr – address from which the testcase starts dumping
endaddr – address on which the testcase stops dumping
inc – address increment for the next step
gaps – array if dictionary, see above example
filename – file to where register values get stored
- tbottest.tc.common.generic_machine_dump_write(typ, machine, filename) None[source]
Write a created register dump in file filename, created with testcase
generic_machine_dump
to the machine machine.
- tbottest.tc.common.lnx_check_cmd(lnx: LinuxShell, cmd_dict) bool[source]
check commands in list of dictionaries cmd_dict. for each element in list execute command cmd_dict[“cmd”] and if cmd_dict[“val”] != “undef” check if cmd_dict[“val”] is in command output
An element without “val” only runs its command, as with “undef”. With “mode”: “exec” its return code does not matter, else (“exec0”, the default) the command must succeed, as for linux_init.
- Parameters:
lnx (machine) – machine on which commands are executed
cmd_dict (dict) – list of dictionary with command and return values.
- tbottest.tc.common.lnx_create_random(lnx: LinuxShell, f: str | Path, len: int) bool[source]
create file f with len bytes and random content
- Parameters:
lnx – linux machine on which the file gets created
f – full path and filename which gets reated, a string or a linux.Path of lnx
len – length of created file
- tbottest.tc.common.lnx_compare_files(lnx: LinuxShell, f1: str, o1: int, f2: str, o2: int, length: int) bool[source]
compare the content of the 2 files f1 @ offset o1 and f2 @ o2 raise RuntimeError if they differ.
- Parameters:
lnx – linux machine on which the files get compared
f1 – full path to first file
o1 – offset in first file
f2 – full path to second file
o2 – offset in first file
length – length (in bytes)
- tbottest.tc.common.lnx_get_hwaddr(lnx: LinuxShell, name: str) str[source]
get the MAC address of a network device, with ip or ifconfig; see tbottest.tc.network.lnx_get_hwaddr(), which this calls
- Parameters:
lnx – linux machine from which we want to get the hwaddr
name – name of the interface
- tbottest.tc.common.lnx_start_bin_with_timeout(lnx: LinuxShell, binary: str, seconds: float) None[source]
start binary binary for n seconds
- Parameters:
lnx – linux machine we work on
binary – name of the binary which get started
seconds – seconds it get executed
- tbottest.tc.common.lnx_wait_for_ip(lnx: LinuxShell, name: str, loops: int, timeout: int, ip6: bool = False) str[source]
wait until ip is set on device name
- Parameters:
lnx – linux machine we run
name – name of the device for which we wait for the ip
ip6 – set to True if you want to get ipv6 ipaddr
loops – maximal wait loops
timeout – timeout if process is not found
- Returns:
ip addr
- tbottest.tc.common.lnx_wait_for_file(lnx: LinuxShell, name: str, loops: int, timeout: int) bool[source]
wait until file with name name is found with “ls -l”
- Parameters:
lnx – linux machine we run
name – name of the file for which we wait
loops – maximal wait loops
timeout – timeout if file is not found
- tbottest.tc.common.lnx_wait_for_module(lnx: LinuxShell, name: str, loops: int, timeout: int) bool[source]
wait until module with name is loaded
- Parameters:
lnx – linux machine we run
name – name of the module for which we wait
loops – maximal wait loops
timeout – timeout if modulename is not found
- tbottest.tc.common.lnx_wait_for_process(lnx: LinuxShell, name: str, loops: int, timeout: int) bool[source]
wait until process with name name is found with pidof
- Parameters:
lnx – linux machine we run
name – name of the process for which we wait
loops – maximal wait loops
timeout – timeout if process is not found
- tbottest.tc.common.board_ub_delete_env(ub: UBootShell | None = None, mtdparts=None) None[source]
erase the MTD partitions defined in mtdparts
- Parameters:
ub – U-Boot machine we run on
mtdparts – List of dictionary with MTD parts we want to delete
mtdparts = [
    {"name":"bootloader", "size":"180000"},
    {"name":"env", "size":"10000"},
    {"name":"env-red", "size":"10000"},
    {"name":"keys", "size":"10000"},
    {"name":"rescue", "size":"3e50000"},
]
- tbottest.tc.common.board_ub_delete_emmc(ub: UBootShell | None = None, device: str = None, erasesz: str = None) None[source]
delete the emmc device
- Parameters:
ub – U-Boot machine we run on
device – U-Boots dev number for the mmc
erasesz – number of blocks which get erased (started from offset 0)
- tbottest.tc.common.board_wait_for_device(lnx: LinuxShell | None = None, device: str | None = None, retries: int = 1, retry_timeout: float = 0.1) None[source]
wait for device until it is up
- Parameters:
lnx – linux machine we work on
device – path to device we wait for
retries – retry count
retry_timeout – float, sleep after device is not up
- tbottest.tc.common.board_set_default(lab: LinuxShell | None = None, ub: UBootShell | None = None, lnx: LinuxShell | None = None, mtdparts=None, device: str = None, erasesz: str = None) None[source]
set board into default state, so we have a clean base for all our tests.
delete SPI NOR
delete emmc
- Parameters:
lab – lab linux machine
ub – U-Boot machine we run on
lnx – board linux machine
mtdparts – List of MTD parts we want to delete
device – U-Boots dev number for the mmc
erasesz – number of blocks which get erased (started from offset 0)
- tbottest.tc.common.lab_check_part_exists_and_create(lab: LinuxShell | None = None, device: str | None = None, partition: str | None = None) None[source]
check if partition exists on device.
ToDo: create it if not
- Parameters:
lab – linux machine we work on
device – device on which the partition must exist
partition – partition name
- tbottest.tc.common.ub_check_i2c_dump(ub, dev, address, i2c_dump) bool[source]
check if i2c dump is correct
- Parameters:
ub – U-Boot Machine we run
dev – i2c dev number
address – i2c addr
i2c_dump – list of dumped lines, see example below
sample_i2c_dump = [
    "0x00: 11 00 00 21 00 01 3f 01 00 7f 00 00 00 00 00 81",
    "0x10: 00 00 3f 00 00 00 00 00 00 00 00 10 ad de xx xx",
]

before ":" start address, after list of values
       'xx' ignore
- tbottest.tc.common.lnx_check_beeper(lnx: LinuxShell | None = None, beeper=None) None[source]
check if dmesg output contains strings in dmesg_list
- Parameters:
lnx – linux machine on which beeper command is executed
beeper – list of dictionwry with infos for beeper
beeper definition example:
beep = [
    {"freq":"440", "length":"1000", "device":"/dev/input/by-path/platform-buzzer-event"},
]
- tbottest.tc.common.lnx_check_dmesg(lnx: LinuxShell | None = None, dmesg_strings=None, dmesg_false_strings=None) bool[source]
check if dmesg output contains strings in dmesg_list
- tbottest.tc.common.lnx_create_file(lnx: LinuxShell | None = None, filename: AnyStr | None = None, filedata: List | None = None) str[source]
create a file with filename on linux machine lnx with lines in array filedata.
example:
scriptname = "/tmp/cansend.sh"
filedata = [
    "#!/bin/sh",
    "",
    "while true;do",
    "    sleep 5",
    "",
    "    cansend can0 15a#1122334455667788",
    "done",
]

lnx_create_file(lab, scriptname, filedata)
- Parameters:
lnx – linux machine on which the file is created
filename – string of the created file
filedata – List of lines
- tbottest.tc.common.lnx_cmd_versions(lnx: LinuxShell, cmds: List[str] | None = None, autoinstall: bool = False, keyindent: str = '') Dict[str, str][source]
find out on lnx which implementation and version the commands have (cmd_get_version() of tbot, asked again even if known), and log them as line for the ini key cmd_versions, see tbottest.cmdversions
- Parameters:
lnx – linux machine
cmds – list of commands, default TBOTTEST_COMMANDS from tbottest.cmdversions (the commands the testcases of tbottest use)
autoinstall – install missing commands where the system can
keyindent – indentation of the key in its ini section, see cmd_versions_to_config() in tbottest.cmdversions
- Returns:
dictionary command -> version string
- tbottest.tc.common.lnx_install_package(lnx: LinuxShell, package: str) bool[source]
detect OS version installed on linux machine and try to install package
- Parameters:
lnx – linux machine on which the package is installed
package – Name of the package
- tbottest.tc.common.tbot_copy_file_to_board(lab: LinuxShell, lnx: LinuxShell, ethdevice: str, filename: str) None[source]
copy file filename from lab host in tmpdir to board on tmpdir
- Parameters:
lab – lab machine where the file can be found
lnx – linux machine to which the file gets copied
ethdevice – ethernet device which is used
filename – name of the file
- tbottest.tc.common.tbot_start_script_on_board(lab: LinuxShell, lnx: LinuxShell, ethdevice: str, scriptname: str)[source]
copy script scriptname from lab host in tftp dir to board on tmpdir and execute it
- Parameters:
lab – lab machine where the script can be found
lnx – linux machine to which the script gets copied
ethdevice – ethernet device which is used
scriptname – name of the script
- tbottest.tc.common.tbot_start_script_on_lab(lab: LinuxShell, lnx: LinuxShell, ethdevice: str, logfilename: str, scriptname: str, labtbottestcasepath: str)[source]
copy an log file to labhost and start script scriptname, which should check, if logfile is Ok.
- Parameters:
lab – lab machine where the script can be found
lnx – linux machine to which the script gets copied
ethdevice – ethernet device which is used
logfilename – logfilename
scriptname – name of the script
labtbottestcasepath – path where the script can be found on lab
- tbottest.tc.common.tbot_start_thread(lnx: LinuxShell | None = None, cmd: str | None = None) UUID[source]
start linux command in thread and return an id
output of the command gets stored in
stdout : f"/tmp/thread_1_{tid}"
stderr : f"/tmp/thread_2_{tid}"
- Parameters:
lnx – linux machine where the command cmd is started in background
cmd – command which gets started in background
- Returns:
uuid.UUID id
- tbottest.tc.common.tbot_stop_thread(tid: UUID | None = None, signal: str | None = None) dict[source]
stop linux command with tid
- Parameters:
lnx – linux machine where the command cmd is started in background
tid – id got from tbot_start_thread
signal – may you need to kill the process with an special signal number
- tbottest.tc.common.lnx_sudo(lnx: LinuxShell) List[str][source]
prefix for a command that needs root rights on lnx
A lab host may be logged in to as root, often without sudo installed (e.g. a lab host built with Yocto), or as a normal user, who needs sudo. Use it as
lab.exec0(*lnx_sudo(lab), "mkdir", "-p", path)
The user id is asked with “id -u” on the first call for a machine (by its name) and kept for every later one; a machine without a name is asked every time.
- Parameters:
lnx – linux machine
- Returns:
[] when logged in as root, else [“sudo”]
- tbottest.tc.common.sudo_subshell(lnx: LinuxShell = None, cmds: List[str] | None = None, password: str = None) list[source]
execute in a sudo subshell the commands in cmds
Best you use a passwordless sudo approach, for example add in /etc/sudoers
<username> ALL=(ALL) NOPASSWD: ALL
If not possible pass the sudo password to this function.
This function is more or less just an example how to execute commands under sudo, because the commands are only executed without any possibility to check the output.
If you need this, see this as an example how to!
- Parameters:
lnx – linux machine where the command cmd is started in background
str – sudo password, pass None (default) if not needed
cmds (list) – list of commands (strings), which are run under sudo
Common generic Testcases
This testcases work without tbot imports
Boot counter
Boot counter testcases.
Generic, they make no assumption about where U-Boot keeps the counter. Whatever the backing store, bootcount_inc() mirrors the value into the running environment on every boot, so “printenv bootcount” reads it for all of them.
What differs from board to board is how Linux puts the counter back to zero after a boot that came up. That is handed in as a callable, and the two common shapes are here as lnx_bootcount_reset_nvmem() and lnx_bootcount_reset_fw_setenv().
- tbottest.tc.bootcount.lnx_bootcount_reset_nvmem(lnx: LinuxShell, device: str = '/sys/bus/nvmem/devices/*rtc*/nvmem') str[source]
reset the boot counter by zeroing the first word of an nvmem device
For boards where U-Boot keeps the counter in a register through CONFIG_BOOTCOUNT_MEM and Linux reaches that register as nvmem. Only the count is cleared, the magic word next to it is left alone.
- Parameters:
lnx – linux machine to run on
device – path of the nvmem device, a shell glob is allowed
- Returns:
the path that was written, for the log
- tbottest.tc.bootcount.lnx_bootcount_reset_fw_setenv(lnx: LinuxShell, name: str = 'bootcount') str[source]
reset the boot counter through fw_setenv
For boards using CONFIG_BOOTCOUNT_ENV, where the counter is a variable in the stored U-Boot environment.
- Parameters:
lnx – linux machine to run on
name – name of the variable
- Returns:
the name that was written, for the log
- tbottest.tc.bootcount.ub_bootcount(ub: UBootShell) int[source]
the boot counter as U-Boot sees it
- Parameters:
ub – U-Boot machine to read from
- tbottest.tc.bootcount.board_ub_bootcount(lab: LinuxShell | None = None, reset: Callable[[LinuxShell], str] | None = None, warm_resets: int = 2) bool[source]
the boot counter counts, and Linux can put it back
Three things, and none of them cares where the counter is stored:
a cold boot starts the count at 1
every warm reset adds one
once Linux has reset it, the next boot is back at 1
The last one is the receipt the A/B fallback depends on. Without it the counter climbs until bootlimit and the board falls back although every boot came up fine.
The board and the lab host are requested once and held, the U-Boot machine is built from the board object rather than requested as a role. Requesting it takes the board with exclusive=True, and an exclusively requested instance is torn down on release, which would power the board off between the resets.
- Parameters:
lab – lab host, requested when not given
reset – called with the linux machine to clear the counter, see lnx_bootcount_reset_nvmem() and lnx_bootcount_reset_fw_setenv(). When None the linux half is skipped and only the counting is checked.
warm_resets – how many warm resets to do
CAN Tests
- tbottest.tc.can.board_setup_can(lnx: LinuxShell, candev: List[str] | None = None, br: str = '500000', tql: str = '500') None[source]
setup the can interface on linux machine
ip needs root rights, so the commands run with sudo unless lnx is logged in as root (
tbottest.tc.common.lnx_sudo()).- Parameters:
lnx – linux machine where we work on
candev – List of candevices which get intialized
br – used bitrate
tql – use tx queuelen
- tbottest.tc.can.lnx_can_write_dump_compare(lnxsend: LinuxShell, senddev: List[str], lnxread: LinuxShell, readdev: List[str], bitrate: str, txqueuelen: str, data: List[dict]) None[source]
send in lnxsend shell with cansend over senddev the data and dump it with candump in lnxread shell on readdev. Use bitrate and txqueuelen
- Parameters:
lnxsend – linux machine from where we send CAN data
senddev – List of device from which we send
lnxread – linux machine where we receive CAN data
readdev – devices from which we read
bitrate – used bitrate
txqueuelen – used txqueuelen
data – List of dictionary, see below
data is an dictionary with format:
{
    "dev": "linux device name",
    "data": "data format strig for cansend",
    "res": "resulting line in dump file created from candump",
}
- tbottest.tc.can.candump_is_canutils(lnx: LinuxShell) bool[source]
True if candump on lnx is the one of canutils (Pengutronix), which has no log format -L and logs frames as
<0x08c> [8] 8c 00 ..., without timestamp and interface. tbot’s cmd_get_version() tells it from the candump of can-utils by its version output.
- tbottest.tc.can.check_cangen_log(log: str, frames: int, dllength: int, candev: str, canutils: bool = False, canid: int | None = None) List[str][source]
Check the candump log of
cangen -I i -L <dllength> -D i -n <frames>.cangen counts the CAN ID up from 0 (wrapping after 0x7FF) and the data, a little endian counter in the first
dllengthbytes, up from 0 (wrapping after 256 ** dllength). So frame n has CAN ID n % 0x800 and data n % 256 ** dllength.With
canidevery frame has this CAN ID, as the frames ofcansequence(canutils) have; withdllength1 their data, a counter in one byte, is checked the same way.The log is the output of
candump -L, or withcanutilsthe output of candump of canutils, which has no interface in its lines and starts with a header line.- Parameters:
log – the output of candump
frames – number of frames cangen sent
dllength – data length cangen used
candev – interface candump read from
canutils – the log comes from candump of canutils
canid – CAN ID of every frame, None for the counting one of cangen
- Returns:
the differences found, an empty list if the log matches
- tbottest.tc.can.candump_log_duration(log: str) float[source]
seconds between the first and the last frame of a
candump -Llog
- tbottest.tc.can.stop_candump_script(pid: str, timeout: int = 2) str[source]
The shell command line that stops the background job pid: SIGTERM, up to timeout seconds for it to end, then SIGKILL, and wait.
It is one command line, so wait collects the job in it and an interactive shell has no message about the ended job left for the next command (it would end up in the output of tbot’s “echo $?”). sleep takes whole seconds, as busybox sleep may know no fractions.
- tbottest.tc.can.stop_candump(lnx: LinuxShell, pid: str, timeout: int = 2) None[source]
Stop the candump started in the background on lnx with process id pid.
candump of canutils only notices SIGTERM when the next frame arrives, its read() of the socket goes on after the signal. So if it still runs after timeout seconds, it is killed with SIGKILL. It writes every frame at once, so nothing gets lost. See
stop_candump_script().- Parameters:
lnx – Linux machine candump runs on
pid – process id of candump
timeout – seconds to wait for candump to end after SIGTERM
- tbottest.tc.can.cangen_sender_canid(lnxsend: LinuxShell) int | None[source]
How lnxsend sends the frames of
board_lnx_cangen().- Parameters:
lnxsend – Linux machine that sends
- Returns:
None for cangen, else CANSEQUENCE_ID, the CAN ID of the frames of cansequence (canutils), when lnxsend has no cangen
- tbottest.tc.can.cangen_config_calls(run: dict) List[Tuple[str, dict]][source]
The calls of
board_lnx_cangen()for one entry of the board configuration keycangen.boarddevandlabdevname the CAN interfaces of the board and of the lab host, a list or a single interface. For every direction ofdirections(default both ofCANGEN_DIRECTIONS) the receiving side gets its interfaces ascandevand candump reads from the first of them, the sending side gets its interfaces ascandevsend. The other keys ofCANGEN_CONFIG_KEYSgo to every call as strings, as a JSON configuration may give numbers.- Parameters:
run – one entry of
cangen- Returns:
the direction and the keyword arguments, without the machines, for every direction
- tbottest.tc.can.board_lnx_cangen(lnx: LinuxShell | None = None, lnxsend: LinuxShell | None = None, tmpdir: str = '/tmp', candev: List[str] | None = None, candevsend: List[str] | None = None, candevdump: str = 'can0', frames: str = '1000', dllength: str = '8', bitrate: str = '500000', txqueuelen: str = '500', cangen_gap: str = '10') None[source]
Send frames with cangen and check what candump received.
For each interface of
candevsend,lnxsendsendsframesframes with incrementing CAN ID and data (cangen -I i -D i), and candump onlnxlogs them fromcandevdumptotmpdiron the board. The log is read back and checked withcheck_cangen_log(): number of frames, interface, CAN IDs, data length and data. The transfer rate comes from the timestamps of the first and the last frame in the log.candump of canutils (Pengutronix, see
candump_is_canutils()) has no log format-L; its log has no interface and no timestamps, so these are not checked and the transfer rate is not reported. canutils has no cangen. Without cangen onlnxsend, the frames are sent withcansequenceof canutils, which sends one data byte with the fixed CAN IDCANSEQUENCE_IDand no gap, sodllengthandcangen_gapdo not apply then.
CPU Tests
- tbottest.tc.cpu.board_lnx_cpufreq(lnx: LinuxShell | None = None, cpufreq=None) None[source]
simple cpufreq setup tests.
look for all elements in cpufreq, if the file in “file” contains the value “val”
- Parameters:
lnx – linux machine we work on
cpufreq – List of dictionary see below
cpufreq = [
    {"file" : "/sys/devices/system/cpu/cpufreq/policy0/scaling_governor", "val" : "performance"},
    {"file" : "/sys/devices/system/cpu/cpufreq/policy0/cpuinfo_max_freq", "val" : "1600000"},
    {"file" : "/sys/devices/system/cpu/cpufreq/policy0/stats/time_in_state", "val" : "0"},
]
- tbottest.tc.cpu.generic_get_socname(lnx: LinuxShell | None = None) None[source]
Try to find out the SoC name.
First approach is to get name through /proc file /proc/device-tree/soc@0/compatible
Currently supported SoC
fsl,imx8mp-soc -> NXP imx8mp -> return “imx8mp” ti,am33xx -> TI am335x -> return “am335x”
The AM335x has no compatible of its own in /proc/device-tree/soc@0, it is taken from the compatible of the root of the device tree.
- Parameters:
lnx – linux machine where we run
- Returns:
see above table, if SoC could not be detected “not detected”
generic board test
- tbottest.tc.generic_board.generic_lnx_check_dump_files(lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
compares for all register dumped into
revfileif they have the same value on linux machine lnx. Register values are read with devmem2 tool.You can configure a
difffileto which found differences are written.- Parameters:
lnx – linux machine where we run
Uses key lnx_dump_files of the board configuration
lnx_dump_files – array of dictionary with configuration for lnx_check_revfile, see
- tbottest.tc.generic_board.generic_lnx_create_dump_files(lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
create a register dump file with name
revfilefromstartaddrtoendaddrwith the devmem2 tool. You find the register file in subdirtbotconfig/BOARDNAME/files/dumpfilesYou need to create this subdir before starting this testcase
Once created this register dump file it can be used with testcase
tbottest.tc.generic_board.generic_lnx_check_dump_files()which will check if all register still have the same value. so for example dump for your current linux kernel the pinmux registers into a dump file and after upgrading to a new linux kernel you can be sure that all pinmux registers stil have the same value!
- Parameters:
lnx – linux machine where we run
Uses key lnx_dump_files of the board configuration
lnx_dump_files – array of dictionary with configuration for lnx_check_revfile
lnx_dump_files = [{"revfile":"name of revfile",

        "startaddr":"startaddress of dump",

        "endaddr":"endaddress of dump",

        "mask":"0xffffffff",

        "readtype":"readtype of devmem2 command",

        "difffile":"file which gets created when there are differences (Set to None to disable it)",

        "timeout":"timeout between devmem2 calls (set to None to disable it)"

        }]
example:
[TC_DUMPFILES_BOARDNAME]
lnx_dump_files = [{"revfile":"control_module.reg", "startaddr":"0x44e10800", "endaddr":"0x44e10808", "mask":"0xffffffff", "readtype":"w", "difffile":"None", "timeout":"None"}]
creates in tbotconfig/BOARDNAME/files/dump the file control_module.reg with content
$ cat tbotconfig/BOARDNAME/files/dumpfiles/control_module.reg
# pinmux
# processor: ToDo
# hardware : ToDo
# Linux    : Linux xxx-board 5.15.105-stable-standard #1 PREEMPT Thu Mar 30 10:48:01 UTC 2023 armv7l armv7l armv7l GNU/Linux
# regaddr mask type defval
0x44e10800 0xffffffff          w 0x00000031
0x44e10804 0xffffffff          w 0x00000031
- tbottest.tc.generic_board.dump_registers(local, socname: str, read, outname: str) None[source]
read the registers of the key regdump with read and dump them with the registermap of socname (scripts/registermap/<socname>_registers.json of the source directory) into outname in the workdir of local; a registermap relative to a base the board sets (the IMMR of the MPC855T) takes it from the key registermap_base
- Parameters:
local – local host
socname – name of the SoC
read – function that reads an address and returns its value
outname – name of the dump file
- tbottest.tc.generic_board.generic_lx_dump_register(lnx: LinuxShell | None = None) bool[source]
Create a register dump on lnx machine, and save it on local hosts workdir in file “generic_registerdump.txt”
The registermap is the one of the SoC the key socname of the board configuration names, else the one generic_get_socname() finds.
- Parameters:
lnx – Linux machine we run on
Uses config variables:
regdump – list of dictionary socname – optional, name of the SoC, e.g. am335x
regdump = [{"address":"0x30340004"}, {"address":"0x30330070"}]
- tbottest.tc.generic_board.generic_ub_dump_register(ub: UBootShell | None = None) int[source]
Create a register dump in U-Boot with md.l, and save it on local hosts workdir in file “generic_registerdump_uboot.txt”, as
generic_lx_dump_register()does in LinuxThe registermap is the one of the SoC the key socname of the board configuration names; there is no /proc/device-tree in U-Boot to find it, and “fdt addr” would overwrite the variable fdtaddr. Without socname the testcase is skipped.
A register of a module whose clock is off may end in a data abort and a reset of U-Boot, so regdump should name registers of modules U-Boot has running.
- Parameters:
ub – U-Boot machine we run on
Uses config variables:
regdump – list of dictionary socname – name of the SoC, e.g. am335x
- tbottest.tc.generic_board.generic_lnx_network_iperf(lab: LinuxShell = None, lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
wrapper for network_linux_iperf with ini file configuration
- Parameters:
lnx – linux machine where we run
iperf – array of dictionary with infos for network_linux_iperf test
ping = [{"ip":"${default:serverip}","retry":"10"}]
- tbottest.tc.generic_board.generic_lnx_network_ping(lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
simple ping test
- Parameters:
lnx – linux machine where we run
ping – array of dictionary with infos for ping
ping = [{"ip":"${default:serverip}","retry":"10"}]
- tbottest.tc.generic_board.generic_lnx_test_beep(lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
make a beep
- Parameters:
lnx – linux machine where we run
Uses config variable beep from BOARDNAME.ini
beep – array of dictionary with infos for beeping
beep = [{"freq": "440", "length":"1000"}]
- tbottest.tc.generic_board.generic_lnx_commands(lnx: LinuxShell | None = None) None[source]
prerequisite: Board boots into linux
- Parameters:
lnx – Linux machine we run on
Uses config variables:
lnx_commands – list of dictionary, see below
lnx_commands = [
   {"cmd":"linux command", "val":"string commandoutput, 'undef' if none"},
   {"mode":"exec", "cmd":"systemctl --all stop my-service"},
   ]
An entry without “val” only runs its command; with “mode”: “exec” its return code does not matter, see
tbottest.tc.common.lnx_check_cmd().
- tbottest.tc.generic_board.generic_lnx_test_dmesg(lnx: LinuxShell | None = None) str[source]
prerequisite: Board boots into linux
call lnx_check_dmesg() which checks dmesg output.
- Parameters:
lnx – Linux machine we run on
Uses config variables:
dmesg – list of strings which must be in dmesg output dmesg_false – list of strings which does not appear in dmesg output
dmesg = [
    "remoteproc remoteproc0: remote processor wkup_m3 is now up",
   ]

dmesg_false = [
   "crash",
   ]
- tbottest.tc.generic_board.generic_lnx_test_led(lnx: LinuxShell | None = None) str[source]
prerequisite: Board boots into linux
switch on and off all leds in list leds
uses lnx_test_led_simple(), see more info there
- Parameters:
lnx – Linux machine we run on
Uses config variables: leds – array of dictionary with infos for leds
leds = [
    {"path":"/sys/class/leds/led-orange", "bootval":"0", "onval":"1"},
]
- tbottest.tc.generic_board.generic_lnx_test_cangen(lab: LinuxShell | None = None, lnx: LinuxShell | None = None) str[source]
prerequisite: Board boots into linux, the lab host has a CAN interface on the CAN bus of the board
sends CAN frames with cangen from the lab host to the board and from the board to the lab host, and the receiving side checks what candump received, with
tbottest.tc.can.board_lnx_cangen(), for every entry of cangen (seetbottest.tc.can.cangen_config_calls())- Parameters:
lab – lab host
lnx – Linux machine of the board
Uses config variables: cangen – array of dictionary with the keys boarddev and labdev, the CAN interfaces of the board and of the lab host, directions, a list of lab2board and board2lab (default both), and the parameters tmpdir, frames, dllength, bitrate, txqueuelen and cangen_gap of board_lnx_cangen, missing ones keep its defaults
cangen = [
    {"boarddev": ["can0"], "labdev": ["can0"], "frames": "1000",
     "dllength": "8", "bitrate": "500000"},
]
If other machines are used, you need a board specific implementation and call board_lnx_cangen().
- tbottest.tc.generic_board.generic_lnx_test_rs485(lab: LinuxShell | None = None, lnx: LinuxShell | None = None) int[source]
prerequisite: Board boots into linux, the lab host has a serial interface on the RS485 line of the board
sends random bytes over RS485 from the lab host to the board and back, with
tbottest.tc.rs485.board_lnx_rs485(), once for every entry of rs485 (seetbottest.tc.rs485.rs485_config_kwargs())- Parameters:
lab – lab host
lnx – Linux machine of the board
Uses config variables: rs485 – array of dictionary, the keys are the parameters ethdevice, rs485labdev, rs485baud, rs485boarddev, rs485lengths and debug of board_lnx_rs485
rs485 = [
    {"ethdevice": "eth0",
     "rs485labdev": "/dev/serial/by-id/usb-FTDI_FT232R_USB_UART_AB0PI210-if00-port0",
     "rs485baud": "115200", "rs485boarddev": ["/dev/ttymxc2"],
     "rs485lengths": ["1", "100"]},
]
- tbottest.tc.generic_board.generic_cmd_versions(lab: LinuxShell | None = None, lnx: LinuxShell | None = None) None[source]
find out which implementation and version the commands tbottest uses have on the lab host, the build host (if tbot.ini has one) and the board, and log a line for the ini key cmd_versions for each, see
tbottest.cmdversionsThe line for the lab host goes into section [LABHOST] (or [LABHOST_<labname>]) of tbot.ini, the one for the build host into its section [BUILDHOST] (or [BUILDHOST_<name>]), the one for the board into section [TC] (or [TC_<boardname>]) of <boardname>.ini.
With tbot flag cmd_versions_install missing commands are installed where the system can (Debian, Ubuntu, Fedora).
- Parameters:
lab – lab host
lnx – linux machine of the board
- tbottest.tc.generic_board.generic_config_to_json(outdir: str | None = None) None[source]
write the configuration of this run as tbot.json and <boardname>.json, see the JSON configuration in generic.rst
From an ini configuration, after set_board_cfg() of boardspecific.py replaced the placeholders, so the files hold the values of this run (e.g. of its flags); replace those with ${flag:…} or ${env:…} where a value depends on them. Values keep their ${…} references, with the tbot flag config_json_resolved they are written resolved, as tbot reads them, to compare two configurations.
- Parameters:
outdir – directory for the two files, default the tbot flag config_json_dir:<dir>, else config-json in the current directory
- tbottest.tc.generic_board.generic_lnx_all(lnx: LinuxShell | None = None) bool[source]
start all configured linux testcases
Runs every testcase of the list
lnxtestcasesin this module and counts it asskipped, if it returns
TC_SKIP, as the testcases decorated withtbottest.tc.generictestdef.require_cfg()do when their key is not in the board configuration,failed, if it raises an exception,
success otherwise.
At the end it logs the counts and the names of the skipped and the failed testcases. It does not raise an exception itself when a testcase failed.
- Returns:
False if a testcase failed, else True
- tbottest.tc.generic_board.generic_kas_get_config(lab: LinuxShell | None = None, bh: LinuxShell | None = None) None[source]
return current kas configuration
- Parameters:
lab – Lab Linux machine
bh – Build host machine
- Returns:
KAS config
- tbottest.tc.generic_board.generic_kas_checkout(lab: LinuxShell | None = None, bh: LinuxShell | None = None) None[source]
checks out all yocto layer we need for our yocto build with the help of the kas tool.
See more in KAS class for configuration.
- Parameters:
lab – Lab Linux machine
bh – Build host machine
- tbottest.tc.generic_board.generic_kas_build(lab: LinuxShell | None = None, bh: LinuxShell | None = None) None[source]
build all targets defined in kas configuration
See more in KAS class for configuration.
- Parameters:
lab – Lab Linux machine
bh – Build host machine
- tbottest.tc.generic_board.generic_kas_check_build(lab: LinuxShell | None = None, bh: LinuxShell | None = None) None[source]
check if oe build finished, if all files listed in kas_check_files exist in deploypath
- Parameters:
lab – Lab Linux machine
bh – Build host machine
Uses config variables: kas_check_files – array of files which must exist
kas_check_files = [
   "tmp/deploy/images/${default:machine}/SPL",
   "tmp/deploy/images/${default:machine}/u-boot.img",
   "tmp/deploy/images/${default:machine}/fitImage",
   "tmp/deploy/sdk/${default:sdk_bin}",
   ]
- tbottest.tc.generic_board.generic_kas_copy(lab: LinuxShell | None = None, bh: LinuxShell | None = None) Path[source]
simply copy all files listed in kas_results from our build host to our lab host.
- Parameters:
lab – Lab Linux machine
bh – Build host machine
Uses config variables: kas_results – list of files
kas_results = [
   "tmp/deploy/images/${default:machine}/SPL",
   "tmp/deploy/images/${default:machine}/u-boot.img",
   "tmp/deploy/images/${default:machine}/fitImage",
]
- tbottest.tc.generic_board.generic_kas_all(lab: LinuxShell | None = None, bh: LinuxShell | None = None) None[source]
simply do all build task in one testcase
Calls:
generic_kas_checkout(lab, bh)generic_kas_build(lab, bh)generic_kas_check_build(lab, bh)generic_kas_copy(lab, bh)- Parameters:
lab – Lab Linux machine
bh – Build host machine
- tbottest.tc.generictestdef.tc_config(func)[source]
Decorator for a testcase that reads the board configuration.
While the testcase runs, its name is the current testcase (see
tbottest.initconfig.init_testcase()), so the configuration is searched in the sectionTC_BOARDNAME.TESTCASENAMEfirst, seetbottest.initconfig.init_get_config().@tbot.testcase @tc_config def my_testcase() -> None: count = cfggeneric.get_config_int("count", "1")
- tbottest.tc.generictestdef.cfg_is_set(value) bool[source]
returns if a value of the board configuration (a string or None) is set. None, an empty string and a Python literal that is false (an empty list, an empty dictionary, 0, False) are not set.
- Parameters:
value – value as init_get_config() returns it
- tbottest.tc.generictestdef.require_cfg(key: str, msg=None)[source]
Decorator for a testcase that needs a key of the board configuration.
It does what
tc_config()does and reads the key when the testcase is called, so a value inTC_BOARDNAME.TESTCASENAMEcounts. If the key is not set (seecfg_is_set()), the testcase is not run. It logsmsgor<testcase> not configuredand returnsTC_SKIP, whichtbottest.tc.generic_board.generic_lnx_all()counts as skipped.@tbot.testcase @require_cfg("dmesg") def generic_lnx_test_dmesg(lnx=None) -> str: ...
- Parameters:
key – key of the board configuration the testcase needs
msg – optional message instead of
<testcase> not configured
HAB (imx specific)
KAS
- tbottest.tc.kas.kas_group_targets(buildtargets) list[source]
the buildtargets, plain target names that follow each other joined with a blank, so that they go to one bitbake call
An entry with a blank (a bitbake command line, an environment setting in front) or starting with “-” stays a call of its own, in its place.
- Parameters:
buildtargets – list of strings, see buildtargets of KAS
- Returns:
list of strings, one per bitbake call
- tbottest.tc.kas.kas_check_mounts(mounts) list[source]
returns mounts as a list, after checking that every entry has the form host:container[:options]
- tbottest.tc.kas.kas_runtime_args_with_mounts(runtime_args, mounts) str[source]
returns the value for kas-container –runtime-args: runtime_args as configured in kas_runtime_args, followed by a “-v <mount>” for each entry of mounts, all in one pair of double quotes. Returns None when there is nothing to pass.
runtime_args may carry its own surrounding quotes, as the kas_runtime_args examples do; they are dropped before the mounts are appended.
- class tbottest.tc.kas.KAS(cfg: dict)[source]
Bases:
objecthelper class for building yocto projects with kas
example:
from kas import KAS

cfgkas = {
    "kasurl" : "url from where kas sources get downloaded",
    "kasversion" : "kas version",
    "build_machine" : "${default:machine}",
    "subdir" : "${default:subdir}",
    "netrc_file" :"/home/${default:build_user}/.netrc",
    "git_credential_store" : "/home/${default:build_user}/.git-credentials",
    "ssh_dir" : "/home/${default:build_user}/.ssh",
    "kascontainer" : @@KASCONTAINER@@,
    "kaslayer" : "${default:kasurl}/${default:kaslayer}.git",
    "kaslayername" : "${default:kaslayer}",
    "kaslayerbranch" : "${default:kaslayerbranch}",
    "kasconfigfile" : "${default:kaslayer}/${default:kasymlname}",
    "kas_runtime_args" : '"--privileged -v ${default:build_dl}:/downloads -v ${default:build_sstate}:/sstate-cache"',
    "bitbakeenvinit" : "sources/poky/oe-init-build-env",
    "envinit" : [""],
    "auto.conf" : [
       'DL_DIR="/downloads"',
       'SSTATE_DIR="/sstate-cache"',
       ],
    "deploypath": "${default:deploydir}",
    "buildtargets" : ["${default:rootfsname}"]
    "bitbakeoptions" : ["-q -q"]
}
kasurl
if you need (or want) to download kas sources from an url, set this.
You do not need to install kas from this sources, as this class simply use run-kas script from within the kas sources.
kasversion
kas version which get checkedout, when you download kas
build_machine
machine name which is used for the build
subdir
based on the build machines workdir, kas sources get checkout into subdir
kas-container
to build with kas-container script set kascontainer to True You may need to pass –git-credential-store to the kas-container script. Set this through:
git_credential_store
You may need to pass –ssh-dir to the kas-container script. Set this Set this through:
ssh_dir
You may need to pass a .netrc file, so set the kas environment varaible NETRC_FILE.
Set this through:
netrc_file
You may want to set the used container engine through KAS_CONTAINER_ENGINE Set this through:
kascontainerengine
You may want to add “–runtime-args” to kas-container, so set
kas_runtime_args
example:
"kas_runtime_args" : '"-v /work/hs/yocto/download:/workdownload"',
You need the
`"`so escape them!tbot flag kaskeepconfig
keeps the repo checkouts and build/conf as they are, like the –keep-config-unchanged option of kas: kas_checkout() does nothing (no pull of the kas config repo, no kas checkout, no auto.conf), and kas shell and kas build get –keep-config-unchanged. It needs one earlier run without the flag, which set the build tree up.
tbot flag kasupdate
passes –update to kas checkout, kas shell and kas build, so kas pulls the newest commit of repos given by a branch, also when the branch is already checked out. Without it kas keeps such a checkout as it is. Ignored with kaskeepconfig, which leaves the checkouts alone anyway.
kas_build_dir
optional build directory, relative to kas_get_basepath(), default “build”. It is passed to kas as KAS_BUILD_DIR, so several kas configurations of one board, e.g. glibc and musl, each keep their own build/conf and can be built one after the other with kaskeepconfig:
"kas_build_dir" : "build-musl",
kas_mounts
list of directories the kas container gets mounted, each as
host:containerorhost:container:options. Every entry becomes a-v <entry>behind kas_runtime_args in “–runtime-args”, for example to give the kas shell a directory with build helper scripts:"kas_mounts" : ["/work/hs/yocto/scripts/build:/scripts:ro"],
kaslayer
sources which contain your kas config file(s). This class downloads them into kas_get_basepath / “kasconfig”
kaslayername
you can give them an unique name
kaslayerbranch
branch which is used
kasconfigfile
kas config file which is used
auto.conf
You can define here an auto.conf file, if you need to add special settings. The file is created after kas_checkout ends.
"auto.conf" : ['DL_DIR="/workdownload"',
              'SSTATE_DIR="/worksstate-cache"',
    ],
site.conf
Lines for build/conf/site.conf, which bitbake reads like local.conf. Unlike auto.conf it is written anew before every kas checkout and kas build, so it is the place for values that change from build to build, e.g. an ID of the build. With the tbot flag kaskeepconfig it is left alone.
"site.conf" : ['MY_BUILD_ID = "1234"'],
bitbakeenvinit
if you are not using a kas container you need to source the oe environment script (and may have to setup more stuff) before you can call bitbake. This entry contains a list of commandstrings, which are executed when kas has checkout the source code. Default is “sources/poky/oe-init-build-env”
envinit
Here you can add additional commands you need, when you build in kas-container
buildtargets
array of strings containing the names of the build targets with which bitbake is called.
If string “bitbake” is in buildtargets, bitbake command is not added to command.
Plain target names that follow each other are built in one bitbake call, see kas_group_targets(): a recipe whose task hash changes from call to call would otherwise be built again in every call, and an image or bundle built in an earlier call would carry an older copy of it than the one deployed last.
For example you can write
"buildtargets" : ["core-image", "DISTRO=poky-rescue bitbake rescueimage-fit", "swu-image"]
which will result in the following bitbake calls
$ bitbake core-image
$ DISTRO=poky-rescue bitbake rescueimage-fit
$ bitbake rescueimage-fit
$ bitbake swu-image
bitbakeoptions
options with which bitbake is called (for example you may want to pass -q) So with above setting:
"bitbakeoptions" : ["-q -q"]
you get the bitbake calls:
$ bitbake -q -q core-image
$ DISTRO=poky-rescue bitbake rescueimage-fit
$ bitbake -q -q rescueimage-fit
$ bitbake -q -q swu-image
- kas_get_basepath() Path[source]
get the basepath where kas works in at your build host
@tbot.testcase
def try_kas_getbasepath(
    lab: Optional[linux.LinuxShell] = None,
    bh: Optional[linux.LinuxShell] = None,
):
    with tbot.ctx() as cx:
        if lab is None:
            lab = cx.request(tbot.role.LabHost)

        if bh is None:
            bh = cx.request(tbot.role.BuildHost)

        cfgkas["labhost"] = lab
        cfgkas["buildhost"] = bh

        kas = KAS(cfgkas)
        val = kas.kas_get_basepath()
- kas_build_dir_env() list[source]
returns the KAS_BUILD_DIR setting for a kas call, if kas_build_dir is configured
- kas_keep_config_args() list[source]
returns the kas option that keeps repo checkouts and build/conf unchanged, if tbot flag kaskeepconfig is set
- kas_update_args() list[source]
returns the kas option that pulls repos given by a branch, if tbot flag kasupdate is set and kaskeepconfig is not
- kas_write_siteconf() None[source]
write the lines of site.conf to build/conf/site.conf, anew every time; nothing with the tbot flag kaskeepconfig
- kas_checkout() None[source]
call “kas checkout” so kas checksout all the needed sources for your ow build, and setup conf directory.
Does nothing with tbot flag kaskeepconfig.
- kas_container_args() tuple[source]
the environment settings and the options kas-container needs for a checkout and for a build alike
- Returns:
(environment settings in front, options after the command)
- kas_build(buildtargets=None) None[source]
build all buildtargets.
LED
- tbottest.tc.leds.lnx_test_led_simple(lnx: LinuxShell | None = None, leds: List[dict] = None) None[source]
simple linux led test. Looks if led file ‘brightness’ has after boot the ‘bootval’ value, than sets the ‘onval’ value, checks if ‘brightness’ file has now this value, and set it back to ‘bootval’.
simple … may we can check gpio register, or i2c gpio expander value… perfect would be to recognize the led through a webcam…
- Parameters:
lab – linux machine we work on
lnx – board linux machine
leds – List of dictionary, see below
leds = [
    {"path":"/sys/class/leds/led_blue", "bootval":"0", "onval":"1"},
    ]
MTD
- tbottest.tc.mtd.lnx_mtd_nvram(lnx: LinuxShell, dev: str = '/dev/mtd0', tests=None) None[source]
write and reread random data on device dev offsets, bytesize and length is defined in array tests which contain dictionary of form
{"bs" : "1", "cnt" : "2", "seek" : "0"}
example:
tests = [
    {"bs" : "1", "cnt" : "2", "seek" : "0"},
    {"bs" : "1", "cnt" : "2", "seek" : "5"},
    {"bs" : "1", "cnt" : "20", "seek" : "5"},
    {"bs" : "1", "cnt" : "26", "seek" : "0"},
]
- tbottest.tc.mtd.lnx_mtd_nvram_reboot(dev: str = '/dev/mtd0', tests=None) None[source]
prerequisite: Board boots into linux
fill device with random data, as defined in tests an reboot and check if the nvram contains the same data after the reboot.
{"bs" : "1", "cnt" : "2", "seek" : "0"}
example:
tests = [
    {"bs" : "1", "cnt" : "2", "seek" : "0"},
    {"bs" : "1", "cnt" : "2", "seek" : "5"},
    {"bs" : "1", "cnt" : "20", "seek" : "5"},
    {"bs" : "1", "cnt" : "26", "seek" : "0"},
]
- tbottest.tc.mtd.lnx_mtd_dump(ethdevice: str = 'eth0', subdir: str = 'dump') None[source]
prerequisite: Board boots into linux, reachable with ssh as root
Works with the board’s linux on the console or, with -fssh, over ssh. Over ssh the md5sums on the board are not disturbed by whatever userspace writes to the console.
Dump every MTD partition of the board into the lab host’s tftp directory, below subdir, and verify each dump against the board.
The board side only reads, through the /dev/mtdrN nodes, which the kernel opens read only. The data goes from the board to the lab host with ssh (“ssh root@<ipaddr> cat /dev/mtdrN”), straight into a file on the lab host. The lab host needs sshpass: the root password from linux_password is handed over with “sshpass -e” in the SSHPASS variable of a subshell, set with tbot’s PasswordAuthenticator.export_sshpass(), so it shows up neither in the command log, nor in a channel trace, nor in the process list. The board computes md5sum of every partition over its console, the lab host does the same on the files, and sizes and sums have to match.
Files written: mtd<N>-<name>.bin per partition, proc-mtd.txt with the board’s /proc/mtd, and md5sums.txt.
network
- tbottest.tc.network.lnx_netcmd(lnx: LinuxShell, prefer: str = 'auto') str[source]
command to configure the network of lnx with, “ip” or “ifconfig”
- Parameters:
lnx – linux machine
prefer – auto (default): ip if lnx has it, else ifconfig, checked with cmd_get_version(“ip”) of tbot (once per machine), not with the exit code of “ip –help”, which iproute2 ends with 255 and busybox with 0. ip or ifconfig: that one, without a check.
The tbot flag useifconfig takes ifconfig on every machine.
The answer is worked out on the first call for a machine and prefer, and returned from _NETCMD on every later one.
- tbottest.tc.network.netmask_to_prefix(netmask: str) int[source]
prefix length of a dotted IPv4 netmask, e.g. 24 for 255.255.255.0
- tbottest.tc.network.classful_prefix(ipaddr: str) int[source]
prefix length the kernel gives an IPv4 address set without netmask (ifconfig <dev> <ipaddr>): by its class, 8 for A, 16 for B, 24 for C
- tbottest.tc.network.ipv4_in_net(addr: str, netaddr: str, prefix: int) bool[source]
- Returns:
True if the IPv4 address addr is in the network of netaddr/prefix
- tbottest.tc.network.lnx_ifdown(lnx: LinuxShell, dev: str, sudo: bool = False, netcmd: str = 'auto') None[source]
take the network device dev down, with ip or ifconfig (lnx_netcmd())
- tbottest.tc.network.lnx_ifup(lnx: LinuxShell, dev: str, sudo: bool = False, netcmd: str = 'auto') None[source]
bring the network device dev up, with ip or ifconfig (lnx_netcmd())
- tbottest.tc.network.lnx_set_ipaddr(lnx: LinuxShell, dev: str, ipaddr: str, netmask: str | None = None, sudo: bool = False, netcmd: str = 'auto') None[source]
set the IPv4 address of dev, taking it down and up again, as “ifconfig <dev> down <ipaddr> [netmask <netmask>] up” does
With ip the old IPv4 addresses of dev are flushed first, as ifconfig replaces the address, and a second call does not fail on an address that is already there. Without netmask the prefix follows the address class, as with ifconfig (classful_prefix()).
- Parameters:
lnx – linux machine
dev – network device, e.g. eth0
ipaddr – IPv4 address
netmask – dotted netmask, or None
sudo – run the commands with root rights (sudo, unless lnx is logged in as root)
netcmd – auto, ip or ifconfig, see lnx_netcmd()
- tbottest.tc.network.lnx_set_ethdevice(lnx: LinuxShell, dev: str, ethcfg: dict, netcmd: str = 'auto') None[source]
set ipaddr and netmask from ethcfg on the ethernet device dev of the board, with ip or with ifconfig
The board configuration sets netcmd with the key linux_netcmd in the [TC] section of the board ini (BOARDNAME.ini): auto (default), ip or ifconfig, see lnx_netcmd(). The flag useifconfig takes ifconfig, whatever linux_netcmd says.
- Parameters:
lnx – linux shell on the board
dev – name of the ethernet device, e.g. eth0
ethcfg – dictionary with the keys ipaddr and netmask
netcmd – auto, ip or ifconfig
- tbottest.tc.network.lnx_has_netdev(lnx: LinuxShell, dev: str, netcmd: str = 'auto') bool[source]
- Returns:
True if lnx has the network device dev
- tbottest.tc.network.lnx_get_hwaddr(lnx: LinuxShell, name: str, netcmd: str = 'auto') str[source]
get the MAC address of a network device
- Parameters:
lnx – linux machine from which we want to get the hwaddr
name – name of the interface
netcmd – auto, ip or ifconfig, see lnx_netcmd()
- tbottest.tc.network.lnx_get_ipaddr(lnx: LinuxShell, name: str, ip6: bool = False, poll: int = 5, sleep: int = 2, netcmd: str = 'auto') str[source]
get the IP address of a network device, polling until it is there
- Parameters:
lnx – linux machine from which we want to get the ipaddr
name – name of the interface
ip6 – set to true if you want the ipv6 addr
poll – if != 0 poll n times to get the ip
sleep – sleep in seconds between polls
netcmd – auto, ip or ifconfig, see lnx_netcmd()
- tbottest.tc.network.lnx_network_up(lnx: LinuxShell, device: str, ip: str, sip: str, retry: int, netmask: str | None = None) None[source]
set ip on device, with ip or ifconfig (lnx_netcmd()), and ping sip
- Parameters:
retry – pings to sip before giving up
netmask – dotted netmask, default by the address class, as ifconfig without netmask
- tbottest.tc.network.network_linux_iperf(lnx: LinuxShell, lnxh: LinuxShell, sip: str = 'unknown', intervall: str = '5', cycles: str = '5', minval: str = '40', filename: str = 'iperf.dat', subject: str = 'unkown') bool[source]
start iperf measurement between lnx and lnxh machine
toolname : iperf (oldversion) or iperf3
lnxh : machine where iperf server runs lnx : machine which start iperf client
interval : seconds between periodic throughput reports cycles : count of intervalls
process
- tbottest.tc.process.process_get_gnuplot_work_and_configpath(local: LinuxShell)[source]
return config and workpath for gnuplot
- tbottest.tc.process.ps_parse_ps(log) None[source]
parse the log output from ps command called with the options
`pid,tid,pcpu,nice,priority,comm", "H", "-C", pname`Warning
This works not with the busybox version
- tbottest.tc.process.ps_parse_top(log, busybox) None[source]
parse the log output from top command called with the options
top -b -n X -d X -c -H | awk ‘($1==”%Cpu(s):”)||($8==”R”)||($1==”MiB”) {print}’
if busybox is True, we get log from busybox output, which is
You get back an arrray containing dictionary
{"loop":<loop>, "cpu_system":<cpu dictionary>, "values",<array of values>}
cpu dictionary contains a dictionary of the form:
{'USER': '93.8', 'SYSTEM': '4.4', 'NICE': '0.0', 'IDLE': '1.8', 'WA': '0.0', 'HI': '0.0', 'SI': '0.0', 'ST': '0.0'}
array of values contain dictionaries of the form:
{'PID': '267', 'USER': 'weston', 'PR': '20', 'NI': '0', 'VIRT': '243672', 'RES': '85304', 'SHR': '13792', 'S': 'R', 'CPU': '62.5', 'MEM': '17.0', 'TIME': '93:29.61', 'CMD': '/usr/bin/weston'}
- tbottest.tc.process.lnx_get_process_cpu_usage(lab: LinuxShell, lnx: LinuxShell, pname: str) None[source]
get the current cpu usage of process with name
`pname`you get back a dict of the following format:
{'PID': '172', 'USER': 'root', 'PR': '20', 'NI': '0', 'VIRT': '14720', 'RES': '4340', 'SHR': '3748', 'S': 'S', 'CPU': '0.0', 'MEM': '0.9', 'TIME': '3:31.29', 'CMD': 'rngd'}
- tbottest.tc.process.lnx_get_cpu_stats(lnx: LinuxShell) None[source]
get cpu stats from top command
you get back a dict of the following format:
{'CPU': '0.0', 'SYS': '20.0', 'NI': '0.0', 'IDLE': '75.0', 'WA': '0.0', 'HI': '0.0', 'SI': '5.0', 'ST': '0.0'}
- tbottest.tc.process.lnx_measure_process(lnx: LinuxShell, pname: str, intervall: float, loops: int) None[source]
measure for a process with name
`pname`the cpu usage with`intervall`and`loops`. If`pname`is empty, measure all processes.Warning
This works not with the busybox version
you get back an array which contains a dictionary with entry
{"loop":<loop>, "values",<array of values>}
Array of values contains a dictionary with, see
tbottest.tc.process.ps_parse_ps()If there is no such process
`values`entry is empty
- tbottest.tc.process.is_busybox(lnx: LinuxShell, cmd: str) bool[source]
detect if we have a busybox version of command
`cmd`uses cmd_get_version() of tbot, so it is found out once per machine
- tbottest.tc.process.lnx_measure_top(lnx: LinuxShell, intervall: float, loops: int) None[source]
call top with intervall
`intervalland`loops`and analyse ityou get back an array which contains a dictionary described in testcase
- tbottest.tc.process.ps_create_measurement_png(local: LinuxShell, pname, intervall, loops, result) None[source]
create a png on local host based on the results result from testcase:
tbottest.tc.process.lnx_measure_process()store the gnuplot data in
tbottest/results/measurements/process/{loops}_{intervall}_{pname}.dat
call gnuplot with the config file
tbottest/results/measurements/process/gnuplot-bar.gp
The output png is stored in
`process-usage.png`. Example for viewing it:$ gwenview process-usage.png
example usage of this testcase:
loops = 30
intervall = 1.0
pname = "QtWebEngineProc"

with tbot.ctx() as cx:
    if lab is None:
        lab = cx.request(tbot.role.LabHost)

    if lnx is None:
        lnx = cx.request(tbot.role.BoardLinux)

    result = lnx_measure_process(lnx, pname, intervall, loops)

    local = cx.request(tbot.role.LocalHost)
    ps_create_measurement_png(local, pname, intervall, loops, result)
- tbottest.tc.process.top_create_measurement_png(local: LinuxShell, intervall, loops, result) None[source]
create a png on local host based on the results result from testcase:
tbottest.tc.process.lnx_measure_top()store the gnuplot data in
tbottest/results/measurements/process/{loops}_{intervall}_top.dat
call gnuplot with the config file
tbottest/results/measurements/process/gnuplot-bar-cpustat.gp
The output png is stored in
`process-usage.png`. Example for viewing it:$ gwenview process-usage.png
example usage of this testcase:
loops = 30
intervall = 1.0

with tbot.ctx() as cx:
    if lab is None:
        lab = cx.request(tbot.role.LabHost)

    if lnx is None:
        lnx = cx.request(tbot.role.BoardLinux)

    result = lnx_measure_top(lnx, intervall, loops)

    local = cx.request(tbot.role.LocalHost)
    top_create_measurement_png(local, intervall, loops, result)
example png:
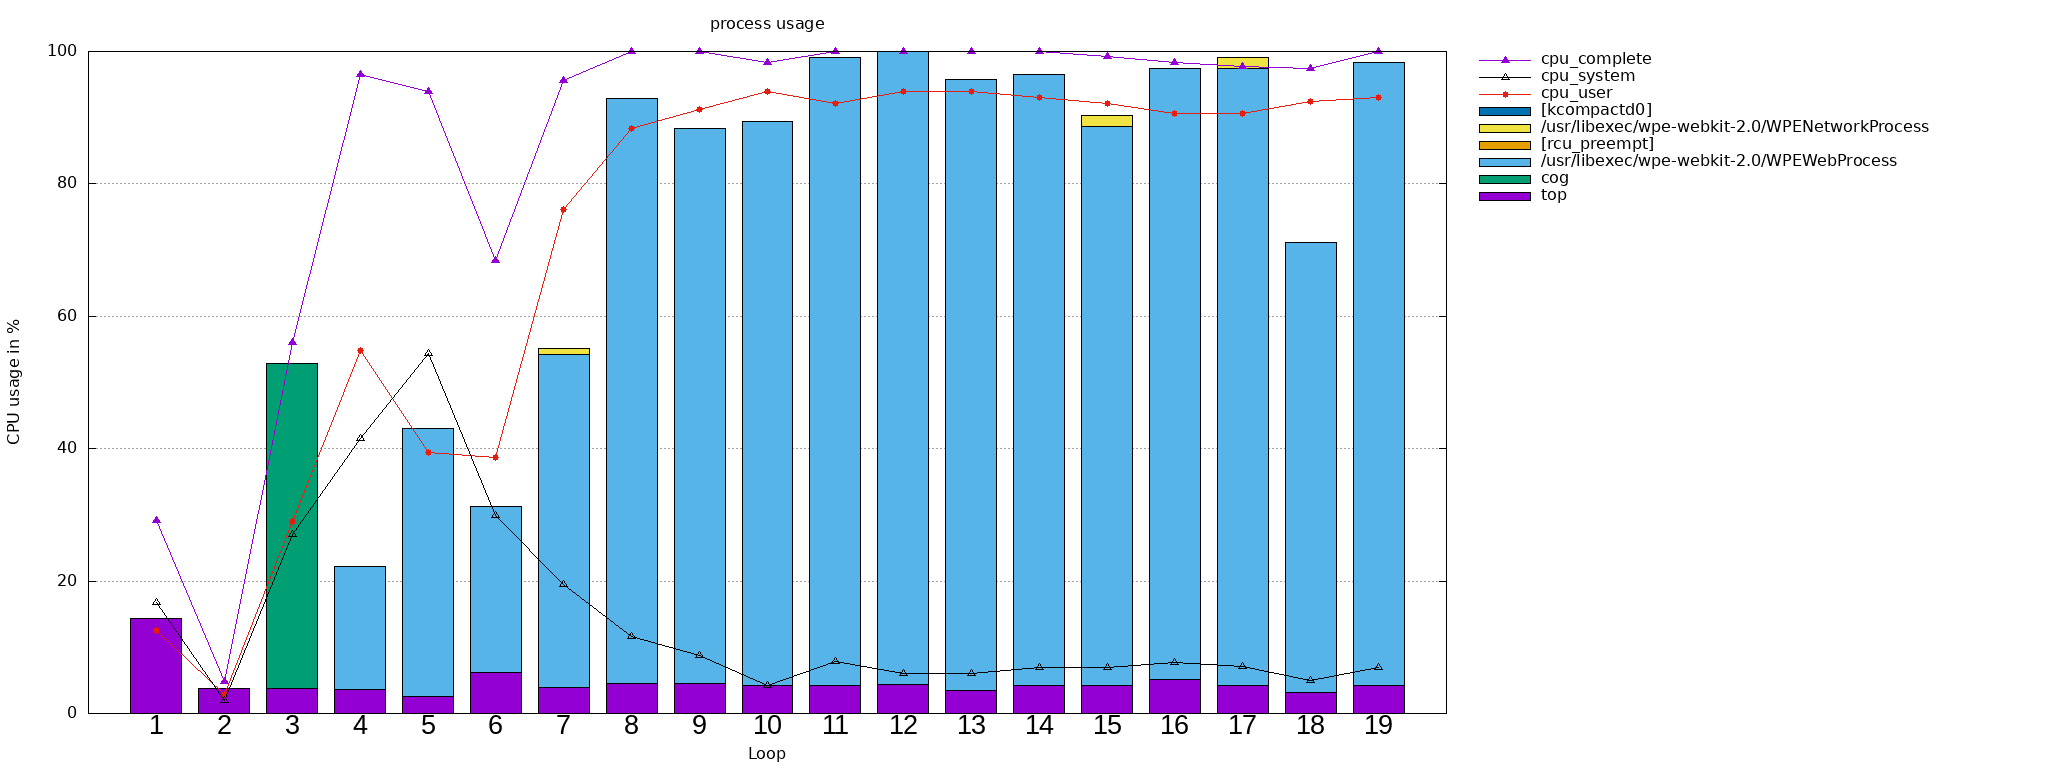
register map
- class tbottest.tc.registermap.REGISTERMAP(mapname: str, socname: str | None = None, base=None)[source]
Bases:
objecthelper class for creating register dumps with analysing the bits from a registermap.
- Parameters:
mapname – name of the registermap file
registermap format for NXP is
[
  {
    "register": "name of the register",
    "address": "address in hex of the regsiter",
    "page": <page in the reference manual>,
    "bits": [
      {
        "range": "bitfiles range example '3' '31-27' ",
        "field": "name of the bitfield",
        "description": "help text from the manuel for the field"
      }
    ]
  },
]
registermap format for STM32MP157 and AM335x is
[
  {
    "peripheralmaps": [
      {
        "bus": "Cortex-A7internal",
        "range": "0xA0026000 - 0xA0027FFF",
        "size": "8KB",
        "peripheral": "GICV",
        "peripheralmap": "GIC virtual CPU interface (GICV)"
      },
    ]
  },
  {
    "registermaps": [
      {
        "mapname": "I2C registers",
        "registers": [
          {
            "registername": "I2C_CR1",
            "offset": "0x00",
            "page": 2559,
            "chapter": "52.9.1",
            "resetvalue": "0x00000000",
            "bits": [
                      {
                        "range": "31:24",
                        "field": "Reserved",
                        "description": "must be kept at reset value."
                      },
            ]
          },
        ]
      },
    ]
  }
]
The registermap contain register mappings for a SoC.
Example for imx8mp:
from tbottest.tc.uboot import ub_read_register
from tbottest.tc.registermap import REGISTERMAP

regmap = REGISTERMAP("imx8mp_registers.json")
with tbot.ctx() as cx:
    if ub is None:
        ub = cx.request(tbot.role.BoardUBoot)

    addresses = ["0x30330070"]
    for address in addresses:
        val = ub_read_register(ub, address)
        regmap.registermap_dump_register(address, val)
Will generate the following register dump
│   ├─[helios-uboot] md.l 0x30330070 1
│   │    ## 30330070: 00000000                             ....
│   ├─-------------------------------
│   ├─register name: IOMUXC_SW_MUX_CTL_PAD_ENET_TXC val: 0x00000000 RM page 1438
│   ├─31-5   -                              val 000000000000000000000000000
│   ├─desc This field is reserved.
│   │ Reserved
│   │
│   ├─--------
│   ├─4      SION                           val 0
│   ├─desc Software Input On Field.
│   │ Force the selected mux mode Input path no matter of MUX_MODE functionality.
│   │ 1 ENABLED — Force input path of pad ENET_TXC
│   │ 0 DISABLED — Input Path is determined by functionality
│   ├─--------
│   ├─3      -                              val 0
│   ├─desc This field is reserved.
│   │ Reserved
│   │
│   ├─--------
│   ├─2-0    MUX_MODE                       val 000
│   ├─desc MUX Mode Select Field.
│   │ Select 1 of 6 iomux modes to be used for pad: ENET_TXC.
│   │ 000 ALT0_CCM_ENET_QOS_CLOCK_GENERATE_TX_CLK — Select mux mode: ALT0 mux port:
│   │ CCM_ENET_QOS_CLOCK_GENERATE_TX_CLK of instance: ccm_enet_qos_clock_generate
│   │ 001 ALT1_ENET_QOS_TX_ER — Select mux mode: ALT1 mux port: ENET_QOS_TX_ER of instance:
│   │ enet_qos
│   │ 010 ALT2_AUDIOMIX_SAI7_TX_DATA[0] — Select mux mode: ALT2 mux port:
│   │ AUDIOMIX_SAI7_TX_DATA00 of instance: sai7
│   │ 101 ALT5_GPIO1_IO[23] — Select mux mode: ALT5 mux port: GPIO1_IO23 of instance: gpio1
│   │ 110 ALT6_USDHC3_DATA1 — Select mux mode: ALT6 mux port: USDHC3_DATA1 of instance:
│   │ usdhc3
│   │
│   ├─--------
There are also helper script in scripts/registermap with which you can generate such a mapping from a reference manual.
A registermap whose first entry has
"relative_to"(e.g."IMMR"for the MPC855T, whose registers lie at an address the board sets) has the ranges of its peripheralmaps as offsets; base is then the address they are relative to.- Parameters:
base – base address of a relative registermap, an int or a hex string
- relative_to()[source]
what the ranges of the peripheralmaps are relative to, None for absolute addresses
- map_base() int[source]
the address the ranges of the peripheralmaps start from: 0, or the base of a relative registermap
- has_peripheralmaps() bool[source]
True for a registermap in the format of the STM32MP157 (peripheralmaps and registermaps, also used for the AM335x), False for the flat list of registers of the i.MX8MP; the format comes from the file, not from the name of the SoC
- get_registername_from_dict() str[source]
return the name of the registername field in the dictionary of the format of the registermap.
- registermap_nxp_search_address(address)[source]
search for the address in the imx8mp registermap
- Parameters:
address – hex string of address
- registermap_stm32mp1_search_address(address)[source]
search for the address in the imx8mp registermap
- Parameters:
address – hex string of address
- registermap_search_address(address)[source]
search for the address in the registermap for the SoC
- Parameters:
address – hex string of address
- registermap_dump_register(address, val) bool[source]
dump the value val which is read from address
This is a first proofe of concept version, the output could be nicer.
- Parameters:
address – hex string of address
val – value hex_string
- registermap_dump_register_file(filepath, address, val) bool[source]
dump the value val which is read from address into a file
This is a first proofe of concept version, the output could be nicer.
- Parameters:
filepath – full path to outputfile
address – hex string of address
val – value hex_string
Example output:
------------------------------------------------------------------------------
register name: IOMUXC_SW_MUX_CTL_PAD_ENET_TXC val: 0x00000000 RM page 1438
------------------------------------------------------------------------------
31-5   -                              val 000000000000000000000000000
desc This field is reserved.
Reserved

...........................................
4      SION                           val 0
desc Software Input On Field.
Force the selected mux mode Input path no matter of MUX_MODE functionality.
1 ENABLED — Force input path of pad ENET_TXC
0 DISABLED — Input Path is determined by functionality
...........................................
3      -                              val 0
desc This field is reserved.
Reserved

...........................................
2-0    MUX_MODE                       val 000
desc MUX Mode Select Field.
Select 1 of 6 iomux modes to be used for pad: ENET_TXC.
000 ALT0_CCM_ENET_QOS_CLOCK_GENERATE_TX_CLK — Select mux mode: ALT0 mux port:
CCM_ENET_QOS_CLOCK_GENERATE_TX_CLK of instance: ccm_enet_qos_clock_generate
001 ALT1_ENET_QOS_TX_ER — Select mux mode: ALT1 mux port: ENET_QOS_TX_ER of instance:
enet_qos
010 ALT2_AUDIOMIX_SAI7_TX_DATA[0] — Select mux mode: ALT2 mux port:
AUDIOMIX_SAI7_TX_DATA00 of instance: sai7
101 ALT5_GPIO1_IO[23] — Select mux mode: ALT5 mux port: GPIO1_IO23 of instance: gpio1
110 ALT6_USDHC3_DATA1 — Select mux mode: ALT6 mux port: USDHC3_DATA1 of instance:
usdhc3
RS485
- tbottest.tc.rs485.rs485_config_kwargs(run: dict) dict[source]
The keyword arguments of
board_lnx_rs485()for one entry of the board configuration keyrs485.rs485boarddev and rs485lengths become lists of strings (a single value a list of one), debug an int, the other keys strings, as a JSON configuration may give numbers. Missing keys are left out, so board_lnx_rs485 reports the ones it needs.
- Parameters:
run – one entry of
rs485- Returns:
the keyword arguments, without the machines
- tbottest.tc.rs485.board_lnx_rs485(lab: LinuxShell | None = None, lnx: LinuxShell | None = None, ethdevice=None, rs485labdev=None, rs485baud=None, rs485boarddev=None, rs485lengths=None, debug=0)[source]
prerequisite: Board boots into linux
simple RS485 test, send and receive some random bytes
- Parameters:
lab – lab machine where we work on
lnx – linux machine where we work on
ethdevice – name of ethernetdevice on labhost used for copying files from board to lab
rs485labdev – path to serial device on lab host for testing rs485 /dev/serial/by-id/usb-FTDI_FT232R_USB_UART_AB0PI210-if00-port0
rs485baud – baudrate used for testing
rs485boarddev – list of paths to serial device(s) on board for rs485 test [“/dev/ttymxc2”]
rs485lengths – list of lengths used for the test
example call
board_lnx_rs485(
    lab,
    lnx,
    ethdevice="eth0",
    rs485labdev="/dev/serial/by-id/usb-FTDI_FT232R_USB_UART_AB0PI210-if00-port0",
    rs485baud="115200",
    rs485boarddev=["/dev/ttymxc2"],
    rs485lengths=["1", "100"],
)
Sensors
- tbottest.tc.sensors.board_lnx_tempsensors(lnx: LinuxShell | None = None, sensors=None) None[source]
prerequisite: Board boots into linux
test temp sensors
- Parameters:
lnx – linux machine where we work on
sensors – List of dictionary, see below
sensors = [{"path":"full path to sensor", "name":"name of the sensor", "tmpvalues":[{"valname":"name of the sensor value", "min":"minimal allowed value", "max":"maximal allowed value"}]}]

sensors = [
    {"path" : "/sys/bus/i2c/drivers/tmp102/0-0048/hwmon/hwmon0", "name" : "tmp102", "tmpvalues" : [{"valname" : "temp1_input", "min" : "0", "max" : "100000"}]},
    {"path" : "/sys/bus/i2c/drivers/tmp102/0-0049/hwmon/hwmon1", "name" : "tmp102", "tmpvalues" : [{"valname" : "temp1_input", "min" : "0", "max" : "100000"}]},
    {"path" : "/sys/bus/i2c/drivers/tmp102/0-004a/hwmon/hwmon2", "name" : "tmp102", "tmpvalues" : [{"valname" : "temp1_input", "min" : "0", "max" : "100000"}]},
    {"path" : "/sys/bus/i2c/drivers/tmp102/0-004b/hwmon/hwmon3", "name" : "tmp102", "tmpvalues" : [{"valname" : "temp1_input", "min" : "0", "max" : "100000"}]},
]
SWUpdate
Testcases for testing devices which use swupdate.
- tbottest.tc.swu.board_lnx_check_swu(lab: LinuxShell | None = None, usesshmachine: bool = False) None[source]
check if swupdate-client.py is installed on lab host if not, try install into lab.toolsdir
- Parameters:
lab – lab machine where we work on
usesshmachine – set to True if you want to use labs sshmachine instead of lab
- tbottest.tc.swu.board_lnx_swu(lab: LinuxShell | None = None, lnx: LinuxShell | None = None, swuimage: str = None, ipaddr: str = None, usesshmachine: bool = False)[source]
install swuimage with swupdate_client.py on lab_host to board with ipaddr.
- Parameters:
lab – lab linux machine
lnx – board linux machine
swuimage – path to swuimage
ipaddr – address of board to where swuimage gets installed
usesshmachine – set to True if you want to use labs sshmachine instead of lab
- tbottest.tc.swu.swu_swupdate_from_file(lab: LinuxShell | None = None, lnx: LinuxShell | None = None, swuimage: str = None) str[source]
update the software with swupdate on the lnx machine.
Use swupdate-image binary on lnx machine with swupdate image swuimage (full path to swuimage)
- Parameters:
lab – lab linux machine
lnx – board linux machine
swuimage – path to swuimage
SWUpdate over the embedded web server.
The bundle is pushed from the lab host with curl, the way the SWUpdate documentation describes it and the way a deployment does it, rather than through a client on the board. tc/swu.py has the other two paths, the swupdate_client.py example from the lab host and swupdate-client on the board itself.
The upload returns as soon as the bundle is in, so whether the update worked is taken from the swupdate journal on the board, read from a cursor taken before the upload. Without that cursor an older run’s success line would answer for this one.
What an update is supposed to change is board specific and stays out of here. board_swu_update() asks the board side for its expectations through a callable, checks them, reboots and checks what came up.
- tbottest.tc.swupdate.SWU_PORT = 8080
default port of the swupdate web server, MG_PORT in mongoose_interface.c
- tbottest.tc.swupdate.SWU_DONE_OK = 'SWUPDATE successful !'
what swupdate notifies at the end of an update, core/notifier.c
- tbottest.tc.swupdate.swu_stop_progress(lnx: LinuxShell, name: str = 'swupdate-progress') bool[source]
keep the board from rebooting the moment an update finishes
swupdate-progress runs with -r and reboots as soon as it sees a successful update. A testcase wants to look at what the update wrote before anything acts on it, and it wants to decide itself when the reboot happens, so the service goes away first. tc/swu.py does the same before its updates.
The service comes back with the next boot, so this is done again for every round rather than once.
- Parameters:
lnx – board linux machine
name – name of the service
- Returns:
whether it was stopped
- tbottest.tc.swupdate.lnx_bootenv(lnx: LinuxShell, name: str) str[source]
read a U-Boot environment variable from linux
- Parameters:
lnx – board linux machine
name – name of the variable
- Returns:
the value, empty string when the variable is not set
- tbottest.tc.swupdate.lnx_mount_source(lnx: LinuxShell, mountpoint: str) str[source]
the device mounted at a mount point
- Parameters:
lnx – board linux machine
mountpoint – path to look up, exactly as /proc/mounts spells it
- Returns:
the device, empty string when nothing is mounted there
- tbottest.tc.swupdate.swu_journal_cursor(lnx: LinuxShell, unit: str = 'swupdate') str[source]
a journal cursor pointing at the end of a unit’s log right now
Everything after it belongs to what happens next, which is what swu_wait_result() reads.
- Parameters:
lnx – board linux machine
unit – name of the systemd unit
- Returns:
the cursor, empty string when journalctl did not give one
- tbottest.tc.swupdate.swu_wait_result(lnx: LinuxShell, cursor: str = '', unit: str = 'swupdate', timeout: int = 900, poll: int = 5) Tuple[bool, str][source]
wait for an update to finish and say whether it worked
- Parameters:
lnx – board linux machine
cursor – journal cursor from swu_journal_cursor(), taken before the upload. Without one the whole log is read, and an older run can answer for this one.
unit – name of the systemd unit
timeout – seconds to wait for a verdict
poll – seconds between two looks at the journal
- Returns:
whether it worked, and the log that says so
- tbottest.tc.swupdate.swu_curl_upload(lab: LinuxShell, swu: str, ipaddr: str, port: int = 8080, timeout: int = 900, field: str = 'file') Tuple[int, str][source]
push a .swu to the board’s web server with curl
Runs on the lab host, so the bundle does not have to be on the board first, and the board installs while it receives.
- Parameters:
lab – lab linux machine, where curl runs and where the bundle is
swu – the bundle, absolute path or a name in the lab’s tftp dir
ipaddr – address of the board
port – port of the swupdate web server
timeout – curl –max-time, the whole transfer
field – name of the multipart field, swupdate takes any
- Returns:
curl’s exit code and its output
- tbottest.tc.swupdate.swu_install(lab: LinuxShell | None = None, lnx: LinuxShell | None = None, swu: str = None, ipaddr: str = None, port: int = 8080, timeout: int = 900) bool[source]
install a bundle and wait for the verdict
Does not reboot, so the caller can look at what the update wrote before anything acts on it. swupdate-progress is stopped for the same reason, see swu_stop_progress().
- Parameters:
lab – lab linux machine
lnx – board linux machine
swu – the bundle, see swu_curl_upload()
ipaddr – address of the board
port – port of the swupdate web server
timeout – seconds for the upload and for the install each
- Returns:
whether the update finished successfully
- tbottest.tc.swupdate.swu_check_bootenv(lnx: LinuxShell, expected: Dict[str, str | None], what: str = '') bool[source]
compare U-Boot environment variables with what they should be
- Parameters:
lnx – board linux machine
expected – variable name to value. A value of None only reports what is there, for something the test cannot know beforehand.
what – added to every message, to tell rounds apart
- Returns:
whether every named variable matched
- tbottest.tc.swupdate.swu_check_mounts(lnx: LinuxShell, expected: Dict[str, str], what: str = '') bool[source]
compare mount points with the devices that should be behind them
- Parameters:
lnx – board linux machine
expected – mount point to device
what – added to every message, to tell rounds apart
- Returns:
whether every mount point matched
- tbottest.tc.swupdate.board_swu_update(lab: LinuxShell | None = None, swu: str = None, ipaddr: str = None, port: int = 8080, expect: Callable[[LinuxShell], Tuple[Dict[str, str | None], Dict[str, str]]] | None = None, check: Callable[[LinuxShell], bool] | None = None, name: str = '', powercycle: bool = False, timeout: int = 900) bool[source]
install a bundle, then boot what it installed and look at it
One round: read the expectations, install, check the environment the update wrote, reboot, and check that the system that came up is the one the environment names.
The board and the lab host are requested once and held, the U-Boot and Linux machines are built from the board object rather than requested as roles. Requesting them takes the board with exclusive=True, and an exclusively requested instance is torn down on release, which would power the board off in the middle of the round.
- Parameters:
lab – lab host, requested when not given
swu – the bundle, see swu_curl_upload()
ipaddr – address of the board
port – port of the swupdate web server
expect – called with the linux machine before the update, with the board in the state the update will change. Returns what the U-Boot environment and the mount points should look like afterwards, as two dicts, see swu_check_bootenv() and swu_check_mounts(). This is where the board specific knowledge sits; nothing in here knows what a bundle means.
check – called with the linux machine of the system that came up, for whatever else a board wants to look at. Returns whether that was in order.
name – what to call this round in the log
powercycle – cut the power instead of rebooting from linux. The eMMC is what the update wrote, so both work, but only this one also proves the ROM picks up a new bootloader from cold.
timeout – seconds for the upload and for the install each
- Returns:
whether everything matched
SystemD
- tbottest.tc.systemd.systemd_stop_service(lnx: LinuxShell | None = None, name: str = '') None[source]
stops a service on linux machine lnx
- Parameters:
lnx – board linux machine
name – name of the systemd service
TPM
- tbottest.tc.tpm.board_lnx_tpm2(lab: LinuxShell | None = None, lnx: LinuxShell | None = None) None[source]
simply check if we find some strings from tpm start check, if tpm has correct major version. And check if eltt2 tool detects correct vendor
TODO: Make this testcase more generic.
- Parameters:
lab – lab linux machine
lnx – board linux machine
Buildinfo
Testcases around /etc/buildinfo.
image-buildinfo of OpenEmbedded writes into every image the values of IMAGE_BUILDINFO_VARS and the revision of every layer it was built from. A test on the board can read them back and see whether it runs the build it is meant to test: a variable that names the build, set once per build, and the commits of the layers that build was made from.
Generic: which variables and layers to check, and what they should say, is handed in.
- tbottest.tc.buildinfo.buildinfo_parse(text: str) Tuple[dict, dict][source]
the variables and the layer revisions of a /etc/buildinfo
A variable that is listed twice gets the value of its last line.
- Parameters:
text – content of /etc/buildinfo
- Returns:
(variables, layers); variables maps name to value, layers maps name to {“branch”: .., “revision”: .., “modified”: True or False}
- tbottest.tc.buildinfo.buildinfo_compare(variables: dict, layers: dict, expected_vars: dict, expected_layers: dict) list[source]
what of a parsed /etc/buildinfo differs from what is expected
A layer revision counts as matching when the one in the file starts with the expected one, so a short commit ID will do. A layer built from a modified checkout does not match.
- Parameters:
variables – variables, see buildinfo_parse()
layers – layers, see buildinfo_parse()
expected_vars – variable name to expected value
expected_layers – layer name to expected revision
- Returns:
list of messages, empty when everything matches
- tbottest.tc.buildinfo.lnx_check_buildinfo(lnx: LinuxShell, expected_vars: dict | None = None, expected_layers: dict | None = None, path: str = '/etc/buildinfo') bool[source]
check /etc/buildinfo on the board against what the build should be
Logs every layer revision found, and every difference.
- Parameters:
lnx – board linux machine
expected_vars – variable name to expected value
expected_layers – layer name to expected revision, a short commit ID will do
path – path of the buildinfo file on the board
- Returns:
True if everything matches
Watchdog
Watchdog testcases.
A watchdog that is never tested is a watchdog that may not work, and the way to test one is to stop feeding it and see the board come back. That is what board_lnx_watchdog_bites() does.
Generic: what feeds the watchdog is a systemd service whose name is handed in, and what a reset looks like from the bootloader is handed in as a callable, because only the board knows which register says so and what it says.
- tbottest.tc.watchdog.lnx_service_main_pid(lnx: LinuxShell, service: str) str[source]
the main PID of a systemd service, empty string when it is not running
- Parameters:
lnx – board linux machine
service – name of the service
- tbottest.tc.watchdog.lnx_pid_holds(lnx: LinuxShell, pid: str, path: str) bool[source]
does this process hold that file open
Reads /proc/<pid>/fd rather than using fuser or lsof, so it works on an image that ships neither.
- Parameters:
lnx – board linux machine
pid – process id as a string
path – the file to look for
- tbottest.tc.watchdog.board_lnx_watchdog_bites(lab: LinuxShell | None = None, service: str = '', device: str = '/dev/watchdog', check: Callable[[Any], bool] | None = None, boot_timeout: float = 120) bool[source]
stop feeding the watchdog and prove that it resets the board
The one test a watchdog cannot pass on paper. Everything up to here can look right, the service can be running and the device can be open, and the watchdog can still be doing nothing because the bootloader never started it or because the kernel is quietly feeding it instead.
The run: check that the service holds the device, stop it, and wait for the board to come up in the bootloader on its own. Nobody asked it to reboot, so arriving there at all is the result. What kind of reset it was is left to the caller through check(), and the board is booted back into linux at the end so it is not left sitting at a prompt.
The board and the lab host are requested once and held, the U-Boot and Linux machines are built from the board object rather than requested as roles. Requesting them takes the board with exclusive=True, and an exclusively requested instance is torn down on release, which would power the board off in the middle of the run and answer the question with a power cycle instead of a watchdog.
- Parameters:
lab – lab host, requested when not given
service – the systemd service that feeds the watchdog
device – the watchdog device that service is expected to hold
check – called with the U-Boot machine that came up after the reset, for whatever the board can say about what kind of reset it was. Returns whether that was the expected kind.
boot_timeout – seconds to wait for the board to come back. The budget is the watchdog timeout, which starts at the last feed just before the service was stopped, plus the boot to the prompt. Set so that a watchdog which does not bite fails the testcase instead of hanging it.
U-Boot
- class tbottest.common.ubootbuild.UBBUILDMAN(lab: LinuxShell, bh: LinuxShell, ubootpatchsubpath: str | None = None, ubootbinariessubpath: str | None = None, defconfig: str | None = None, resultbins: list = [], makelist: list = [])[source]
Bases:
objectsimple class for some useful buildman tool abstractions for building U-Boot. You can define a subdirname “binsubpath” which is a subdir on lab hosts tftp directory in which needed binaries for complete and working U-Boot build are found. tbot copies all files found in this subdirectory to U-Boots build directory on build host.
Same for downsream patches. You can define a name for a subdirectory found on labhosts tftp directory for the board with name “ubootpatchsubpath”. All patches found in this directory, are copied to U-Boot source directory on build host and applied to the current U-Boot source code.
The list of resulting binaries in resultbins you can copy to lab hosts tftp path with
You may need to call also some make targets you can add through list of strings in makelist
- Parameters:
lab – lab host machine. must be valid
bh – build host machine, must be valid
ubootpatchsubpath – str subdir on labhosts tftp directory with downstream U-Boot patches
defconfig – defconfig name of the board
binariessubpath – str subdir on labhosts tftp directory where needed binaries are found
resultbins – list of strings of resulting binarienames
makelist – list of strings of make targets
B = [
{
    'defconfig': 'foo',
    'ubootpatchsubpath': 'uboot-patches',
    'binsubpath': 'binaries',
    'resultbinaries': ['flash.bin'],
    'makelist': ['flash.bin'],
},
]

for b in B:
    bmcfg = UBBUILDMAN(lab, bh, b["ubootpatchsubpath"], b["binsubath"], b["defconfig"], b["resultbinaries"])
    bmcfg.bm_build_board()
    bmcfg.bm_copy_results2lab()
Yocto
- tbottest.tc.yocto.yocto_sdk_envcmd_from_log(log: str, sdk_install_path: str)[source]
returns the path of the environment setup script from the output of the SDK installer, which ends with a line like “ $ . <sdk_install_path>/environment-setup-<target>”, or None
- tbottest.tc.yocto.check_yocto_build_install_sdk(lnx: LinuxShell = None, sdk_install_path: str = None, sdk_path: str = None, sdk_name: str = None) None[source]
install SDK.
- Parameters:
lnx – board linux machine
sdk_install_path – path to where the SDK gets installed
sdk_path – path where to find the SDK installation scirpt
sdk_name – SDK installation scripts name
- Returns:
path of the environment setup script, also kept for check_yocto_sdk_get_scriptname()
- tbottest.tc.yocto.check_yocto_sdk_get_scriptname(lnx: LinuxShell = None) None[source]
return scriptname of installed SDK
- Parameters:
lnx – board linux machine
- tbottest.tc.yocto.check_yocto_sdk_build_hello(lnx: LinuxShell = None, envcmd: str = None, builddir: Path = None) Path[source]
build a hello world program with an installed SDK
- Parameters:
lnx – linux machine the SDK is installed on
envcmd – environment setup script of the SDK, as check_yocto_build_install_sdk() returns it
builddir – directory on lnx, created if missing
- Returns:
path of the program on lnx; run on the target it prints SDK_HELLO_OUTPUT